Learning-path illustrations
Original technical diagrams created for this curriculum on October 14, 2026. They are released under the repository's MIT license. No third-party photographs, search-result thumbnails, logos, or paper figures were copied into these assets.
Each figure has an editable SVG for the course website and a PNG for notes/slides. Labels and worked examples are part of the lesson rather than decorative artwork.
| Figure | Purpose | Files |
|---|---|---|
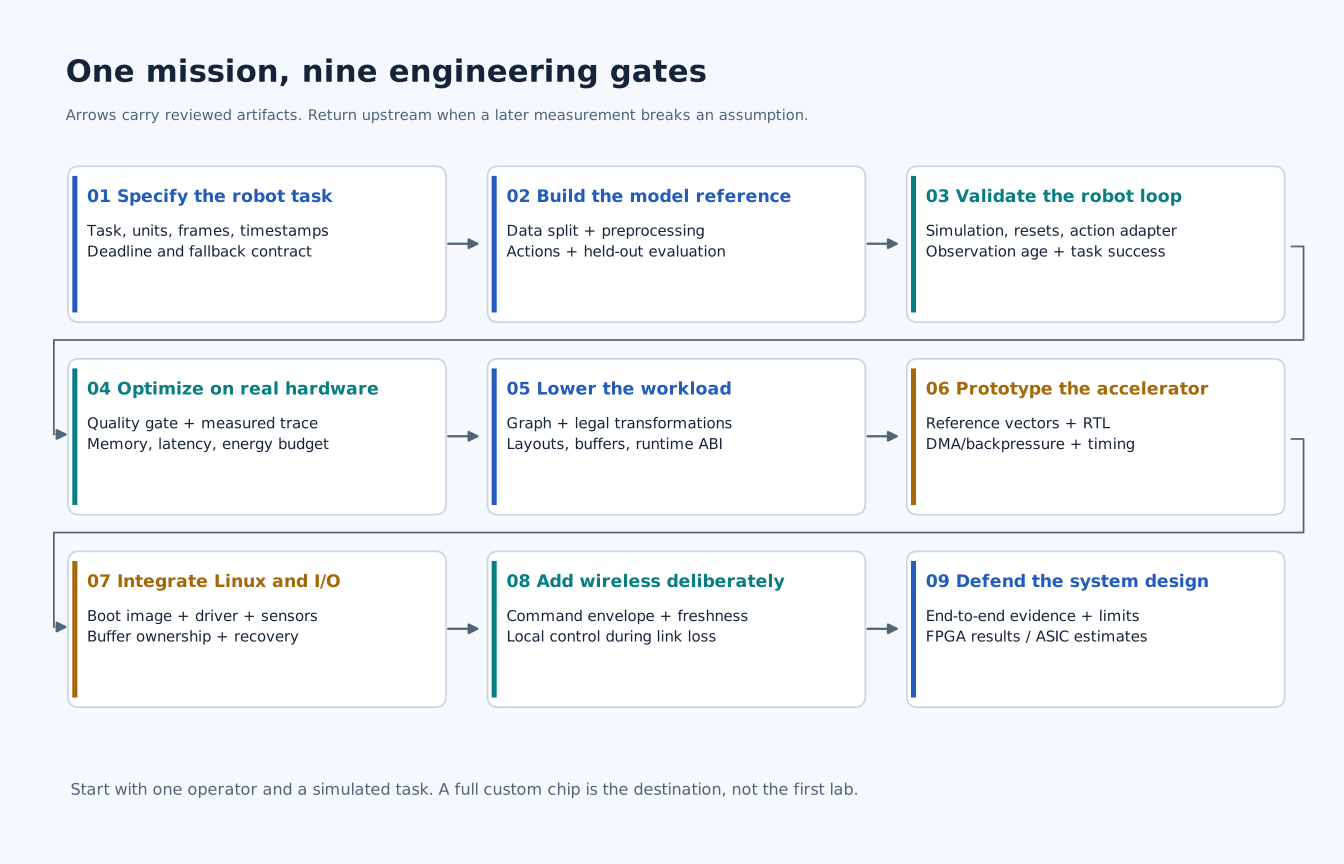
| Mission gates | Connect model, robot, compiler, accelerator, Linux, and wireless deliverables | SVG · PNG |
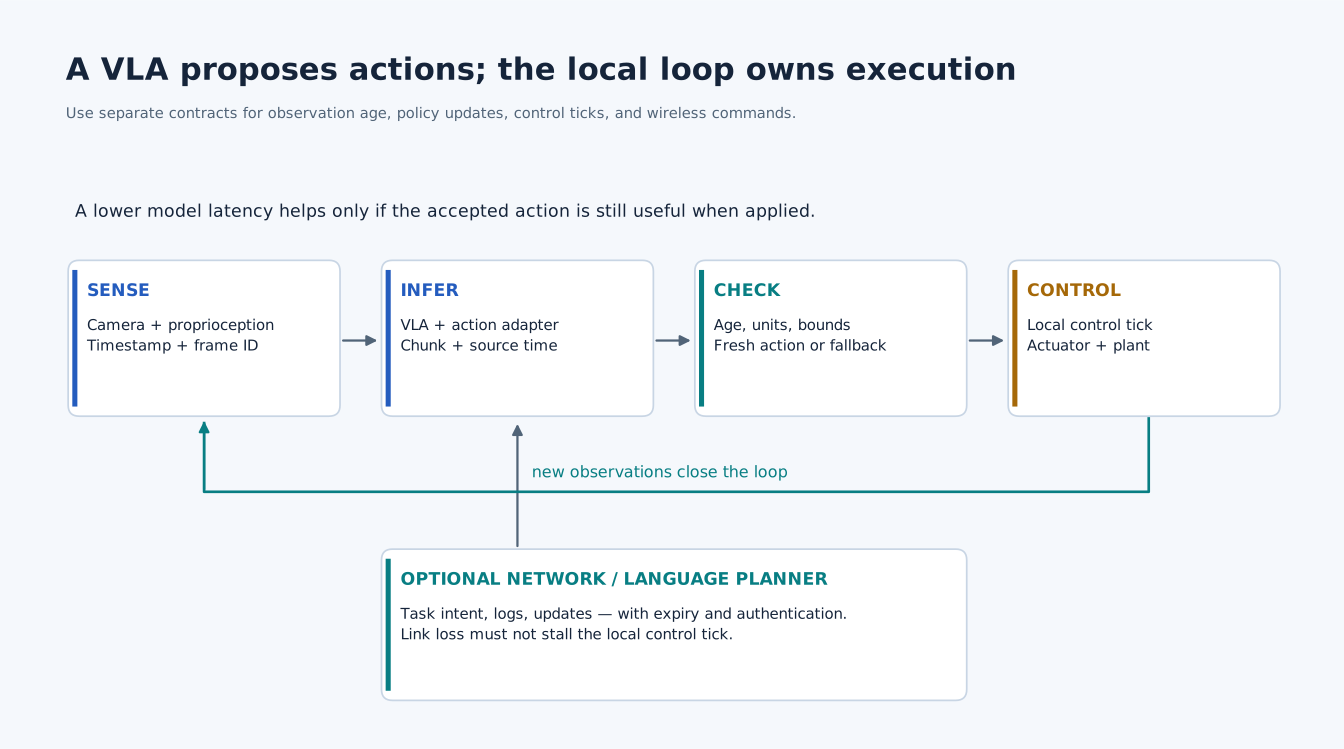
| Robot loop | Distinguish policy, freshness checks, local control, and optional network planning | SVG · PNG |
| Critical path | Explain overlap using a fully specified two-tile analytical example | SVG · PNG |
| NVFP4 storage | Distinguish payload, block scales, tensor scale, and full allocation | SVG · PNG |
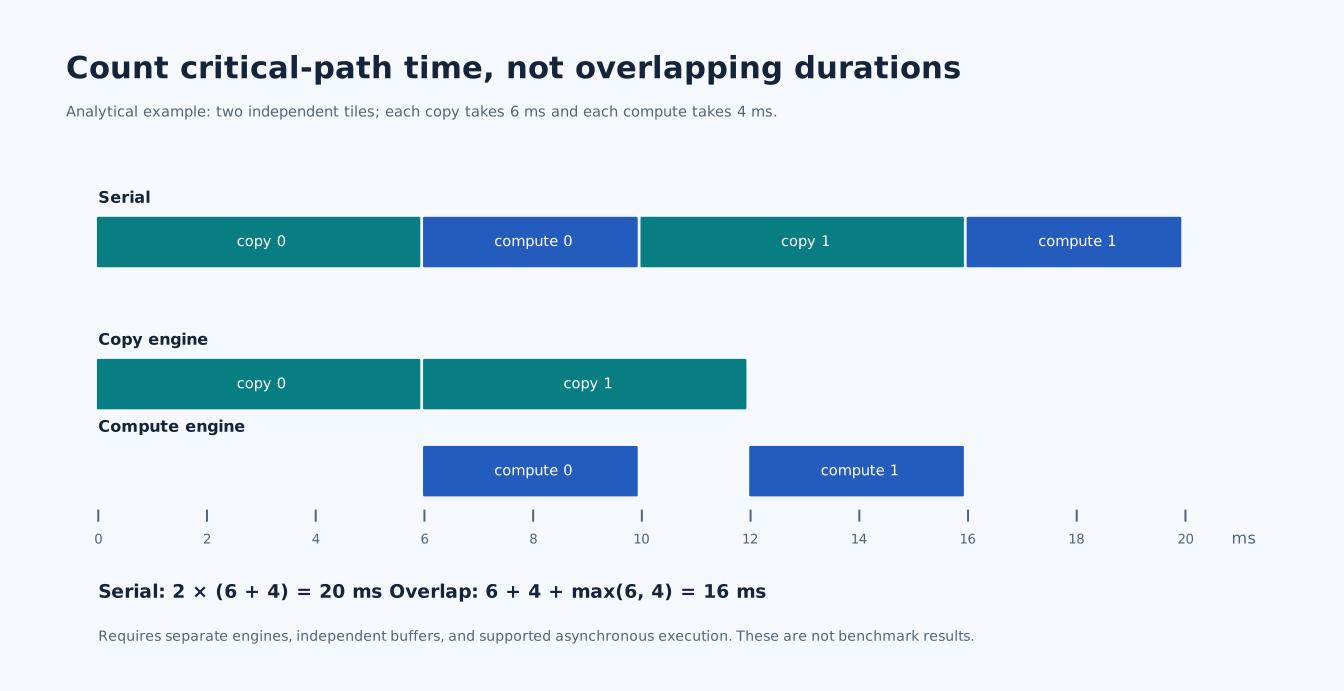
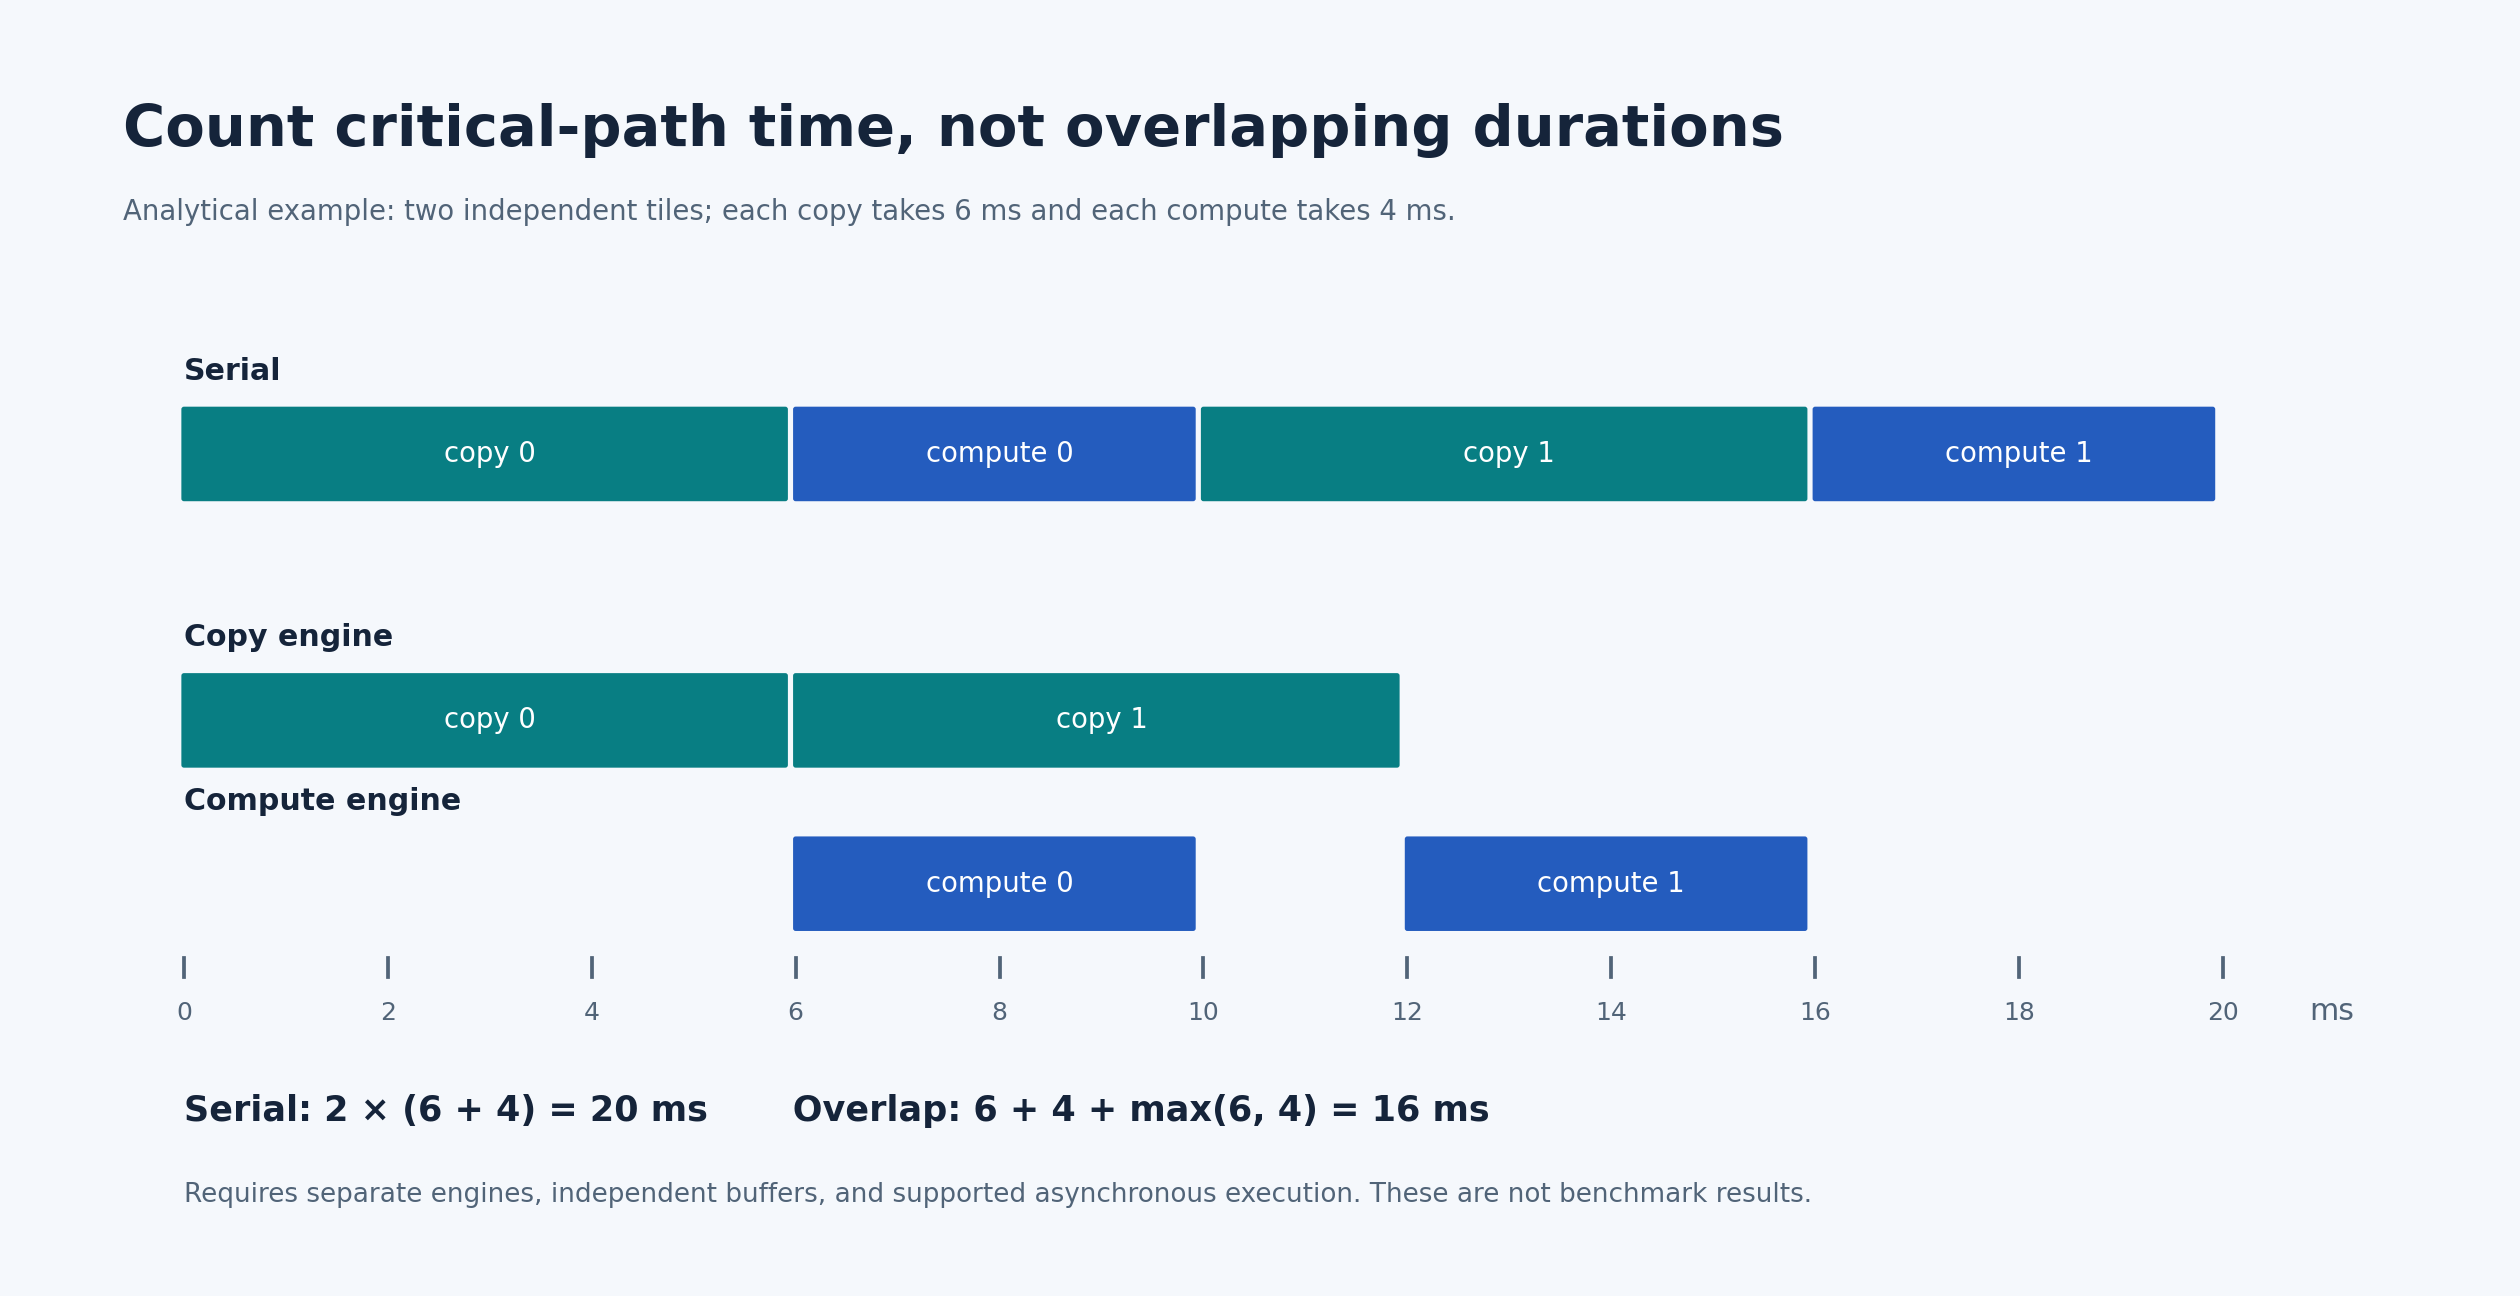
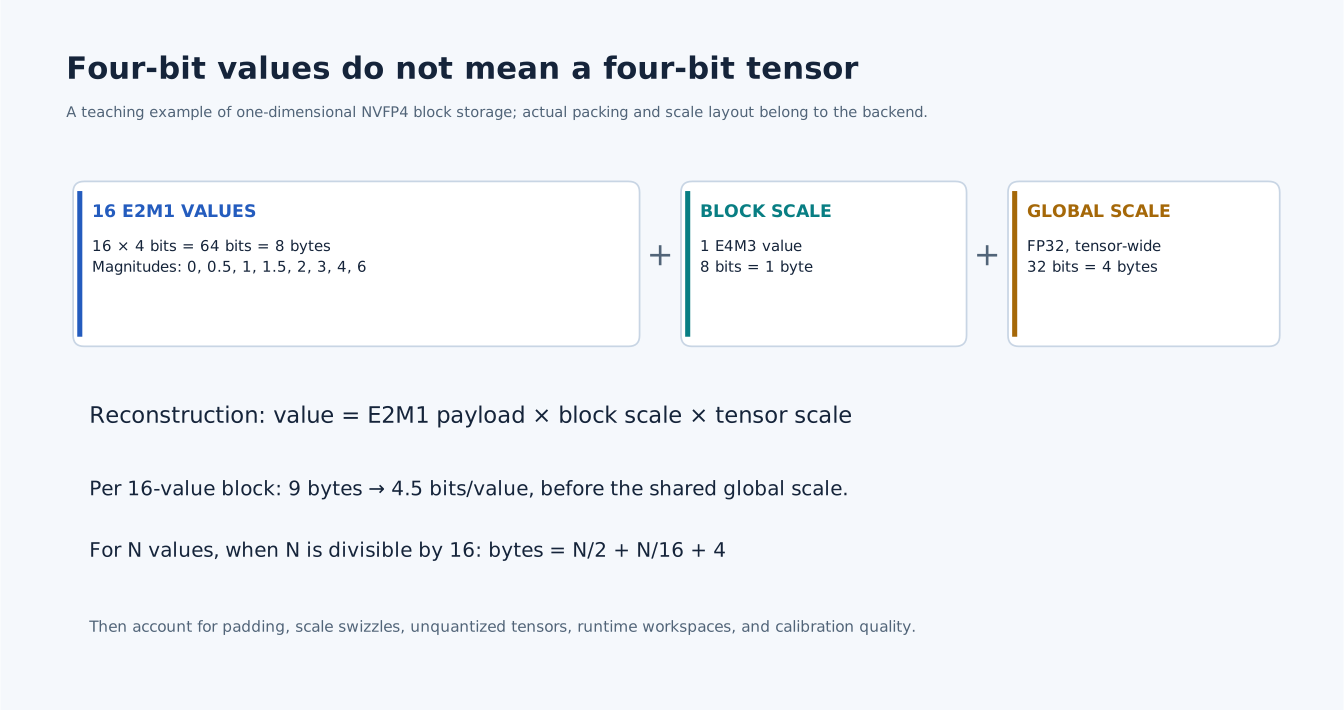
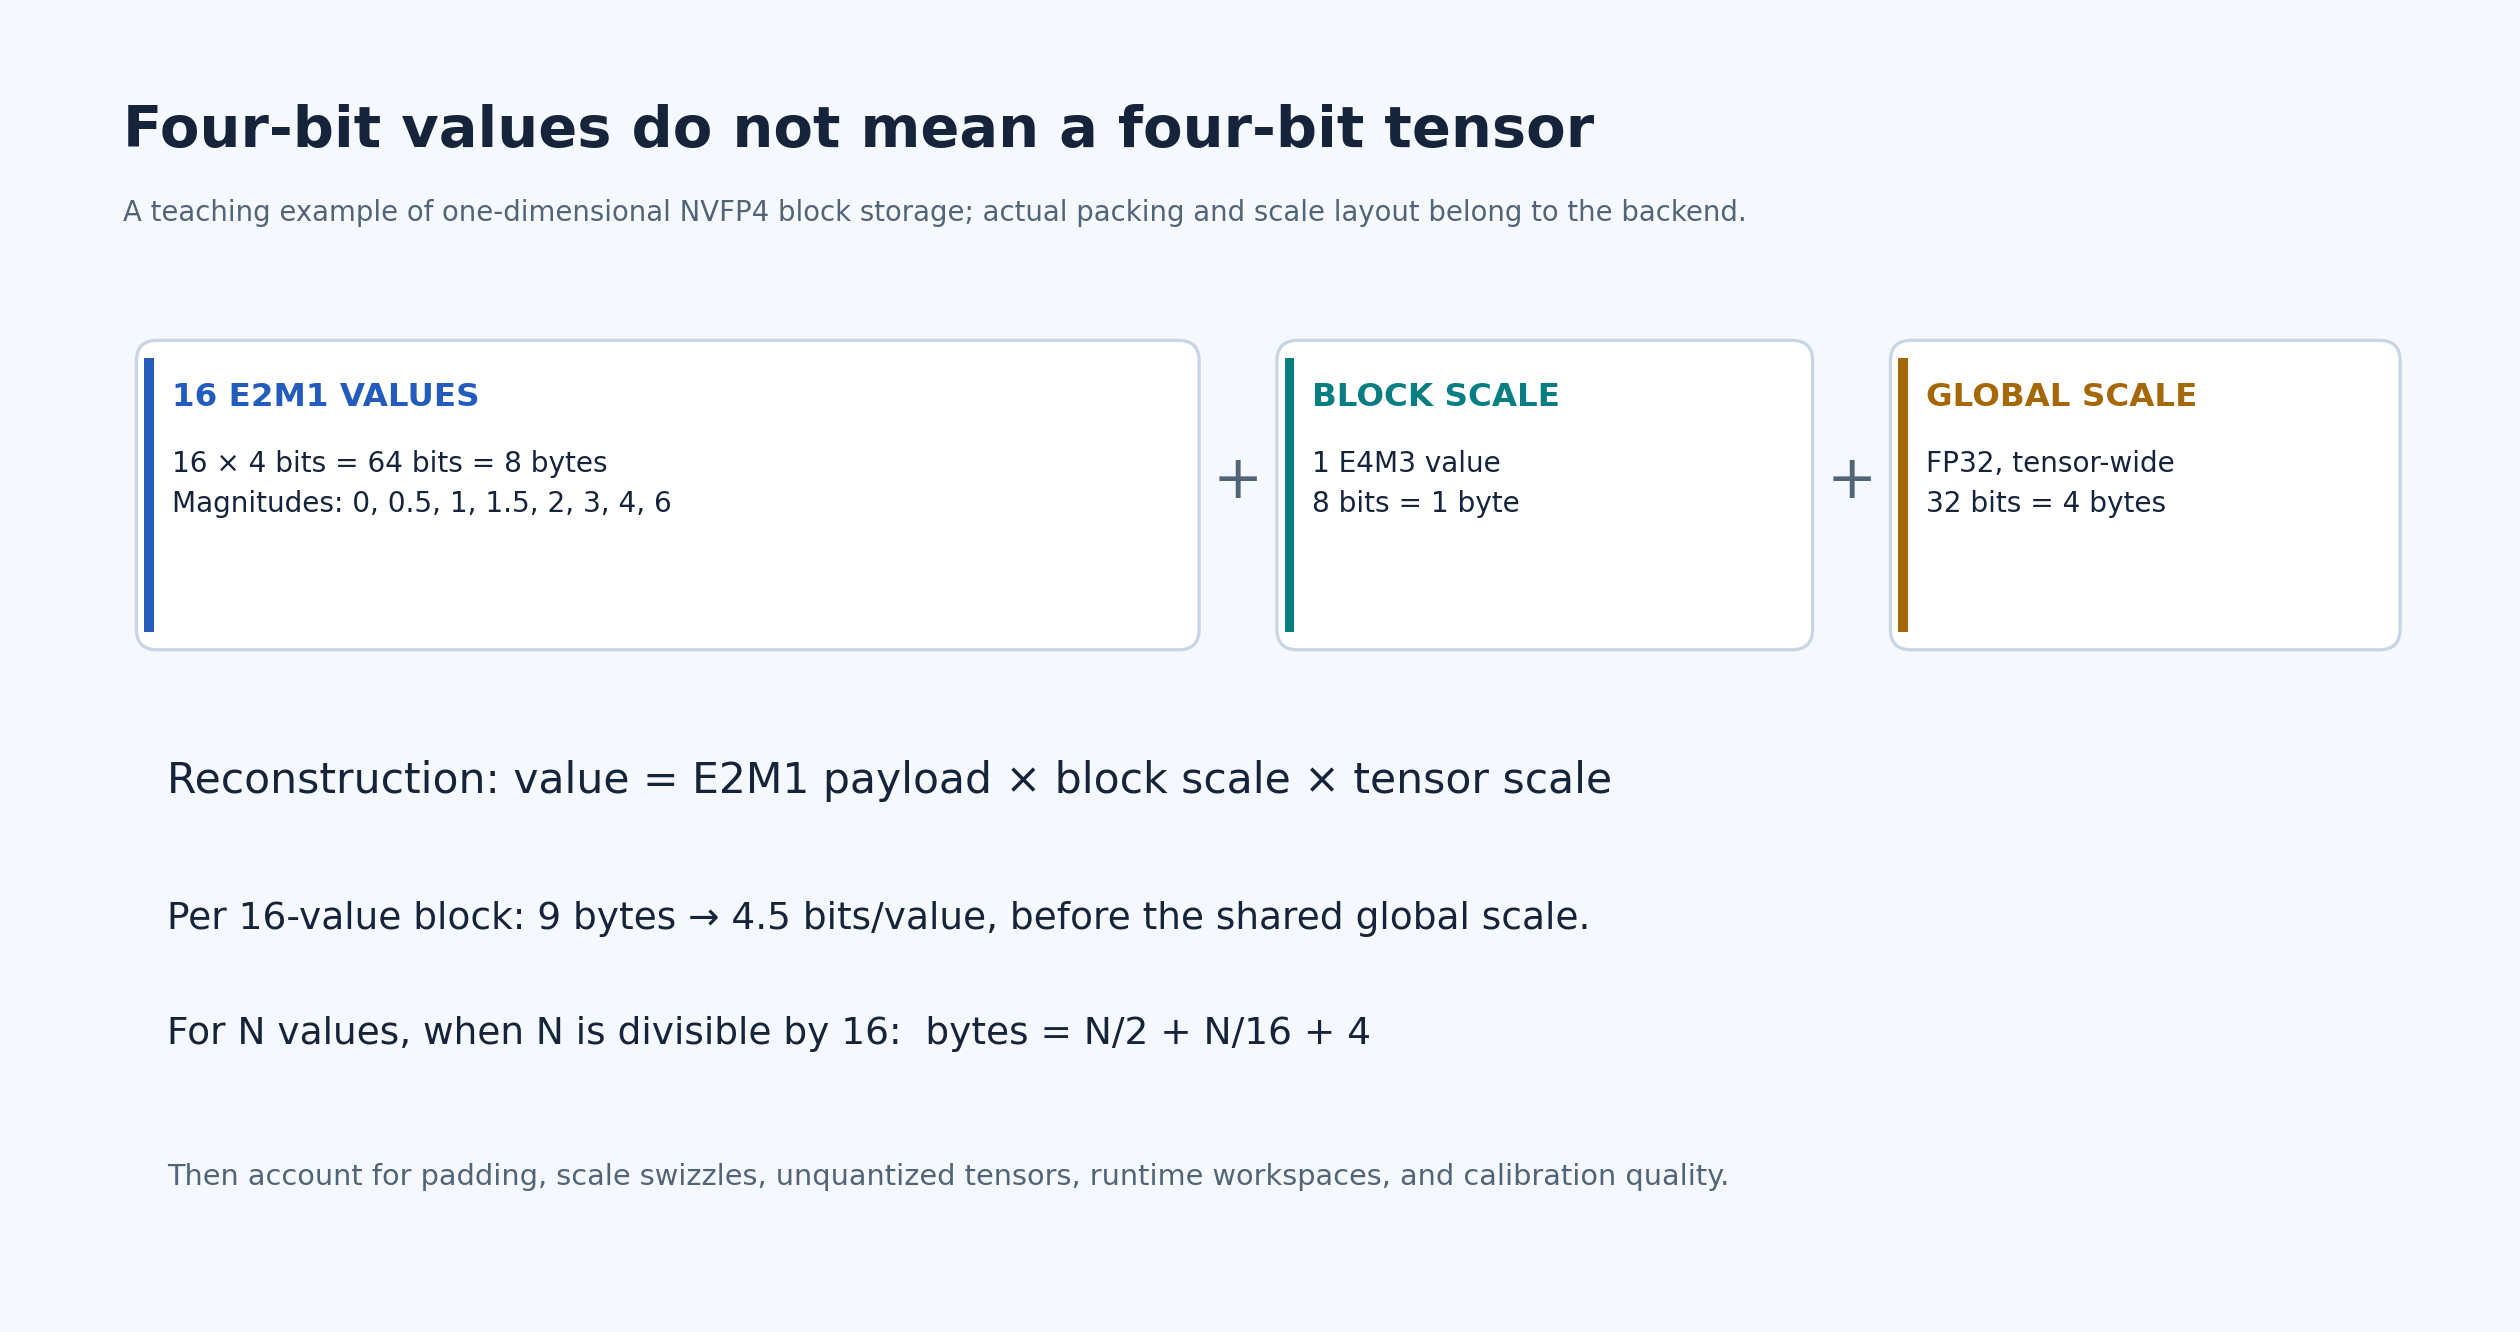
The first three are original curriculum explanations. The fourth illustrates the common one-dimensional layout described by NVIDIA Transformer Engine; it is not copied from a vendor figure and does not describe every training recipe or checkpoint packing convention.
Regenerate from the repository root using Python and Matplotlib:
The source sets SVG text to remain text and PNG resolution to 180 dpi. A font or Matplotlib change may change layout; inspect all four outputs after regeneration. Inline Markdown supplies descriptive alt text and a lesson question. The diagrams use labels as well as color.