Systems, infrastructure, vehicles, and chip-design review
Reviewed 2026-10-14. Scope: Phase 5 overview plus Tracks A, B, E, and F. 32 course/entry pages were individually inventoried; the table records actual review depth. “Entry reviewed” does not mean every associated lecture, command, benchmark, or hardware combination has been independently validated.
The largest change is replacement of unsupported Blackwell performance/quality tables and nonvalidated command recipes with sourced mechanisms, worked budgets, and a reproducible experimental sequence. The AI-chip guide now carries a numerical and executable contract from VLA subgraph through compiler, runtime, Linux driver, and hardware prototype. Existing role catalogs and historical material remain where not directly contradicted by this review.
| Course entry | Review depth | Defect/change | Outgoing artifact | Source basis |
|---|---|---|---|---|
| Guide.md | Full entry | Replaced disconnected specialization endpoint with a behavior → trace → compiler/hardware → integration path. | Versioned workload and implementation-maturity evidence. | Curriculum synthesis |
| A / Guide.md | Full entry | Made cluster study conditional on an actual capacity/throughput constraint; connected ordered investigations. | Operator distribution, memory and communication trace. | Curriculum synthesis |
| A / AMD GPU/Guide.md | Full entry; targeted porting claims | Corrected universal wave-size/bank-count claims and container-as-hardware implication. Added tail-sensitive reduction experiment. | Portable kernel and architecture-specific performance explanation. | AMD HIP performance guidance |
| A / Accelerator Platform Evaluation/Guide.md | Structure and evaluation sections | Recast platform rankings as workload-dependent hypotheses; separated vendor results and measurements. | Quality/SLO-controlled decision table. | Existing vendor references retained; no cross-vendor benchmark run |
| A / Distributed AI Interconnects/Guide.md | Structure, stack, topology framing | Separated management reachability, data-path reachability, and collective success. | Rank-placement and communication matrix. | Existing transport references retained; conceptual experiment |
| A / Nvidia GPU/Guide.md | Full entry | Fixed GEMM expansion; added host-versus-device timing diagnostic. | Two traces selecting the next bottleneck study. | Stable BLAS definition; existing CUDA references |
| A / Nvidia GPU/HPC Setup/Guide.md | Full entry; subcourse inventory | Added layered bring-up sequence and evidence requirements. | Topology/version/runbook baseline. | Existing CUDA/NCCL references |
| A / Nvidia GPU/HPC Setup/8x-H200-Training-Inference/README.md | Full entry; hardware lecture targeted | Removed current-flagship/CXL assumptions, distinguished dense/sparse peaks, fixed guaranteed AllReduce bandwidth in architecture lecture. | Per-rank memory and correctly normalized utilization. | NVIDIA H200 specifications; nccl-tests definitions |
| A / Nvidia GPU/HPC Setup/L40S-x12-Inference/README.md | Full entry; specs/memory review | Fixed sparse precision label; removed unsupported prices/model-size caps; corrected 70B BF16 two-GPU implication. | PCIe placement and memory worksheet. | NVIDIA L40S specifications |
| A / Nvidia GPU/HPC Setup/NCCL-Deep-Dive/README.md | Full entry; introductory claims | Removed fabricated 250× example; added dimensional AllReduce bandwidth calculation. | Correctness-checked message-size sweep. | NVIDIA nccl-tests PERFORMANCE.md |
| A / Nvidia GPU/HPC Setup/CUDA-Advanced-Optimization/README.md | Full entry; introductory claims | Removed universal optimization percentage ladder and zero-overhead promises. | Trace-backed choice of technique. | CUDA programming guide |
| A / Nvidia GPU/HPC Setup/GPUDirect-Storage/README.md | Full entry; data-path/version claims | Separated payload path from CPU control and compatibility fallback; distinguished historical nvidia-fs component version. | I/O mode, CPU usage, loader-time comparison. | NVIDIA GDS overview |
| A / Nvidia GPU/HPC Setup/Confidential-Computing-Attestation/README.md | Full entry; claim-binding lecture reviewed | Removed two-vendor-compromise guarantee; separated authenticated nonce bytes from computation correctness. | Freshness/session/workload threat-boundary tests. | NVIDIA attestation documentation |
| A / Nvidia GPU/HPC Setup/Long-Context-MoE-Foundation-Training/README.md | Full entry; syllabus review | Distinguished modeled/small-model completion from cluster results; total/active/resident expert parameters. | History/expert-sensitive operator and memory trace. | Existing primary training sources; no training run |
| A / Nvidia GPU/HPC Setup/Blackwell-B200-Qwen-Inference/README.md | Full entry; chapters 1–4 and 6 rewritten; chapter 5 targeted | Removed unsupported internal benchmarks and format CLI; fixed B200/GB200/NVL72 boundaries; separated NVFP4/MXFP4; corrected persistent scheduling. | Inventory → format manifest → KV budget → placement → service dossier. | NVIDIA DGX/GB200, CUTLASS, TE, Model Optimizer/TRT-LLM; Qwen config |
| B / Guide.md | Full entry | Removed mandatory cluster-track prerequisite for single-GPU library work. | Measured primitive as accelerator baseline. | Curriculum synthesis |
| B / CUDA-X Libraries/Guide.md | Catalog structure and math sections | Added non-square/transposed/padded-stride GEMM investigation and end-to-end packing costs. | Operation contract and latency/traffic table. | Existing library references; lab not executed |
| E / Guide.md | Full entry | Connected six modules through one scenario and fixed system-level handoff. | Sensor/action/timing contract for chip design. | Official openpilot safety scope |
| E / 1. Fundamentals/Guide.md | Full entry | Corrected DETR3D multi-camera classification and unsupported Stanley/openpilot association; added delayed-observation calculation. | Timestamped perception/control trace. | DETR3D paper; teaching kinematics |
| E / 2. openpilot Reference Stack/Guide.md | Full entry; historical source comparison | Corrected Cap’n Proto vs msgpack, vehicle CAN encoding vs pandad, model outputs vs actuation, replay vs closed loop. | Message ownership and action-interface trace. | openpilot v0.9.7 card.py/log.capnp; official safety docs |
| E / 2. openpilot Reference Stack/agnos/Guide.md | Mapping structure; kernel-version sections | Removed implied io_uring presence; differentiated candidate source maps from observed patches/config/runtime. | BSP feature and buffer-ownership matrix. | comma SDM845 kernel source |
| E / 2. openpilot Reference Stack/camerad/Guide.md | Overview/configuration; ownership-focused review | Added revision boundary and buffer-lifecycle/observation-age experiment. | Frame lifetime and copy/latency budget. | Existing camera source references; no camera bench |
| E / 3. tinygrad for Inference/Guide.md | Concept/setup/decomposition and backend framing | Removed unreadable-PyTorch/line-count claims; corrected fixed IR taxonomy and added version-aware schedule experiment. | Checked subgraph and access pattern. | tinygrad maintained developer documentation |
| E / 3. tinygrad for Inference/README.md | Full entry | Removed universal fusion/view guarantees; added pinned environment workflow. | Correct result plus observed execution path. | tinygrad environment and developer docs |
| E / 3. tinygrad for Inference/ops/README.md | Full operations entry | Corrected reductions-always-break-fusion and fixed primitive count; clarified view/materialization distinction. | Predicted versus observed reduction schedule. | tinygrad developer docs |
| E / 3. tinygrad for Inference/projects/README.md | Project sequence/setup and backend sections | Added same-input chain across tensor/scheduler/backend projects and edge-shape tests; corrected fusion assumption. | Backend shape corpus, generated code, unsupported cases. | tinygrad developer docs; projects not executed |
| E / 4. Advanced Perception and Prediction/Guide.md | Full entry | Corrected Kalibr LiDAR claim, sensor taxonomy and all-weather/radial-velocity overclaims; added time/extrinsic ablations. | Calibration and worst-scenario resource contract. | Kalibr official capabilities |
| E / 5. Safety Standards and Deployment/Guide.md | Full entry; scope source check | Separated safety-goal ASIL, SOTIF, HIL vs simulation, and OpenSCENARIO/OSI roles; removed generic 99% safety threshold. | Hazard → requirement → response → test chain. | ISO 26262/21448 official scope; ASAM OpenSCENARIO |
| E / 6. Lauterbach TRACE32 Debug/Guide.md | Full entry | Added observer-effect, timestamp/trace-loss, measured-maximum vs bound distinctions. | Annotated interrupt/completion trace and visibility requirements. | Existing vendor manuals; tool/hardware not exercised |
| F / Guide.md | Full architecture/flow and framework section; compiler lectures 3–4 targeted | Replaced competitive hype with executable subgraph contract; worked SRAM/KV budgets; corrected synthesis/energy and GDS/tapeout conflations. | Simulator/RTL/driver ABI with explicit maturity and numerical evidence. | CUDA, vLLM graph design, MLIR bufferization |
| F / RISC-V-AI-Chip-Design-and-Market/Guide.md | Structure, patterns, K3 and capstone sections | Labeled vendor specifications and market hypotheses; separated CPU ISA, accelerator queue, VLEN, datapath, Linux/radio enablement. | Block diagram and software-enablement matrix. | RISC-V ISA specifications; Canonical platform announcement |
| F / Agentic Chip Design 2026/Guide.md | Full entry and available Lecture 01 | Removed unsupported event/product backdrop; corrected pass@k/repair metrics and erroneous RTL prerequisite; added independently checked FIFO workshop. | Bounded repair protocol and verified interface candidate. | ChipNeMo; NVlabs VerilogEval |
Primary references checked for substantive corrections
- AMD HIP performance and LDS; NVIDIA H200; NVIDIA L40S.
- nccl-tests bandwidth definitions; GDS overview; attestation scope.
- DGX B200 guide; GB200 topology; CUTLASS Blackwell.
- NVFP4 recipe; Model Optimizer export; TensorRT-LLM quantization support; Qwen config.
- openpilot safety; historical vehicle-control source; historical Cap’n Proto schema; SDM845 kernel.
- Kalibr; DETR3D; ASAM; ISO 26262 scope; ISO 21448 scope.
- tinygrad compiler; MLIR bufferization; vLLM CUDA Graphs; CUDA guide.
- ChipNeMo; VerilogEval maintained harness; RISC-V ISA; Canonical K3/K1 announcement.
Illustration and validation boundary
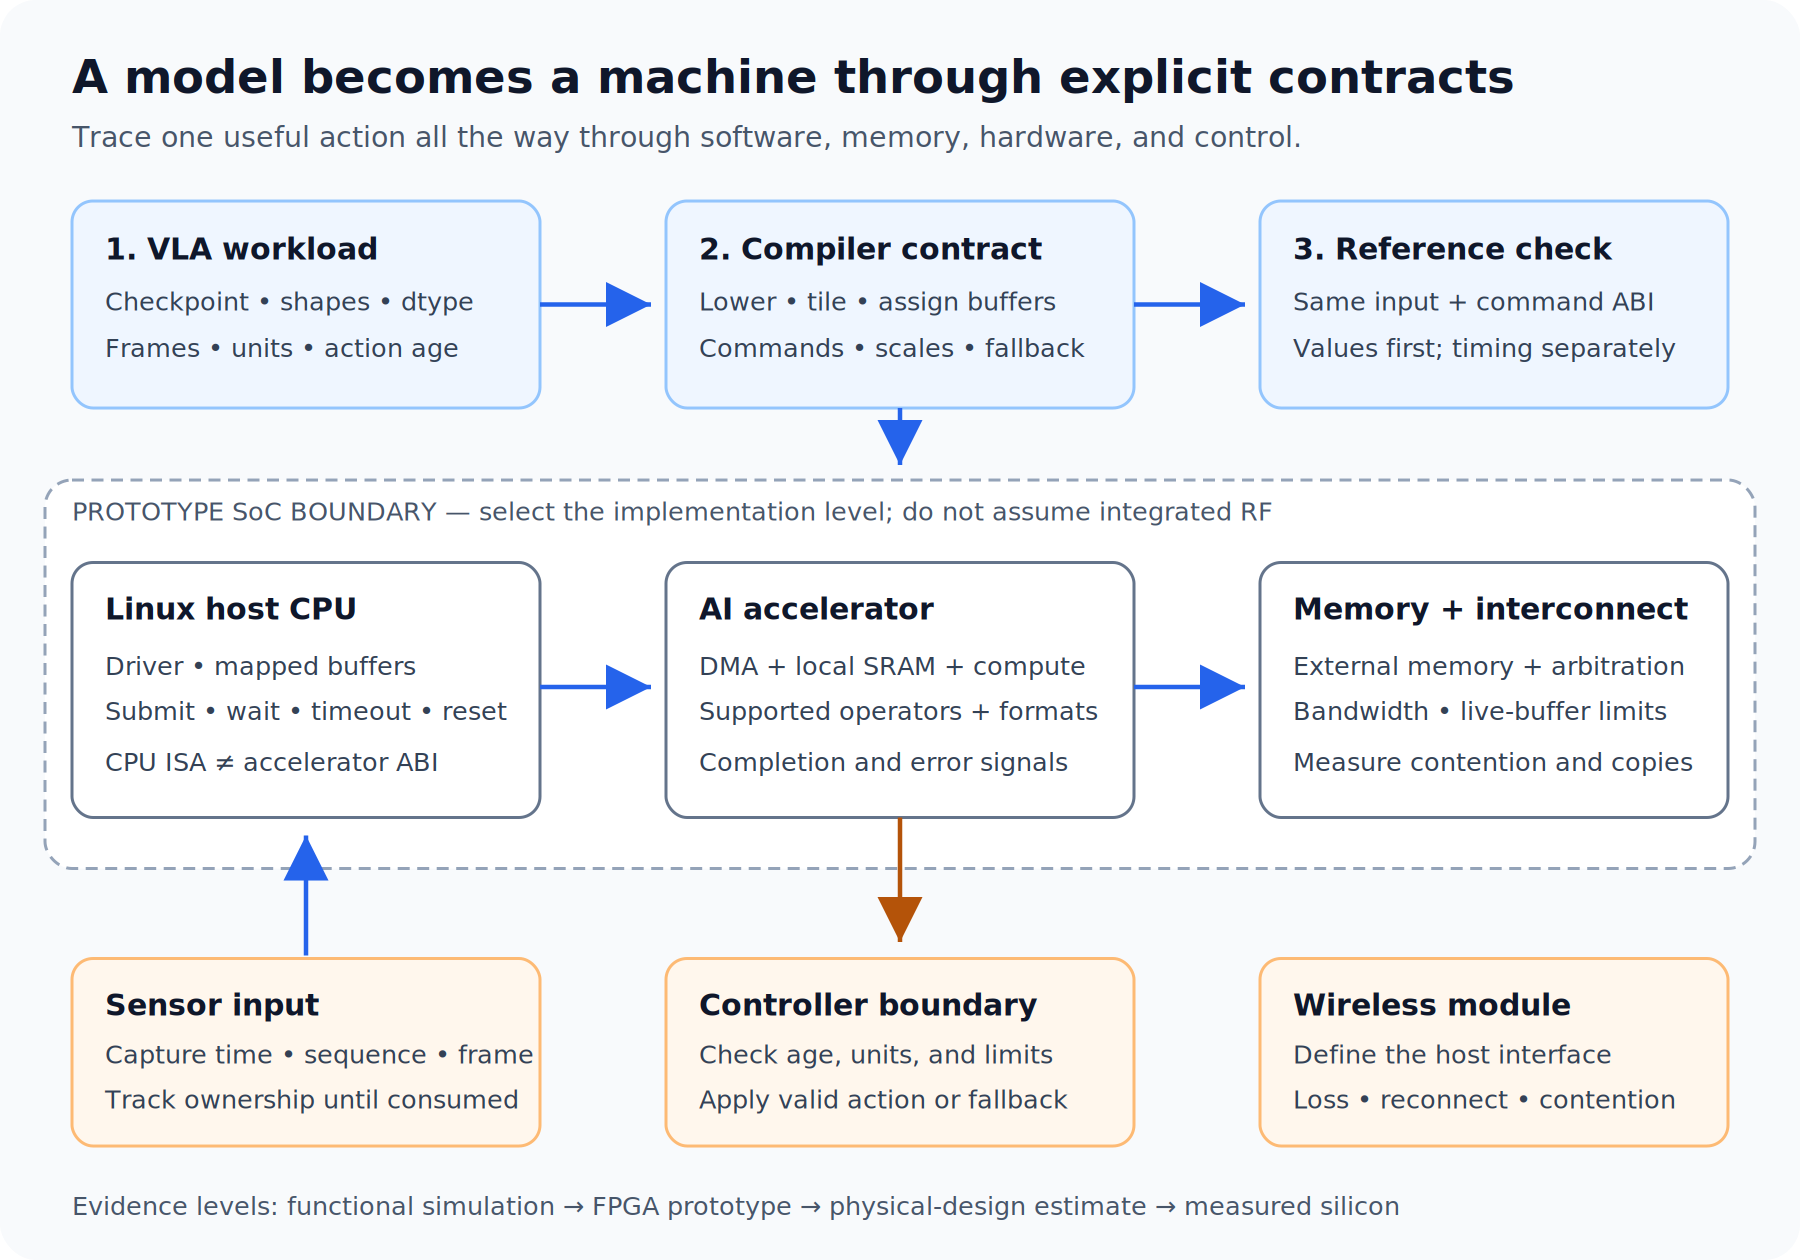
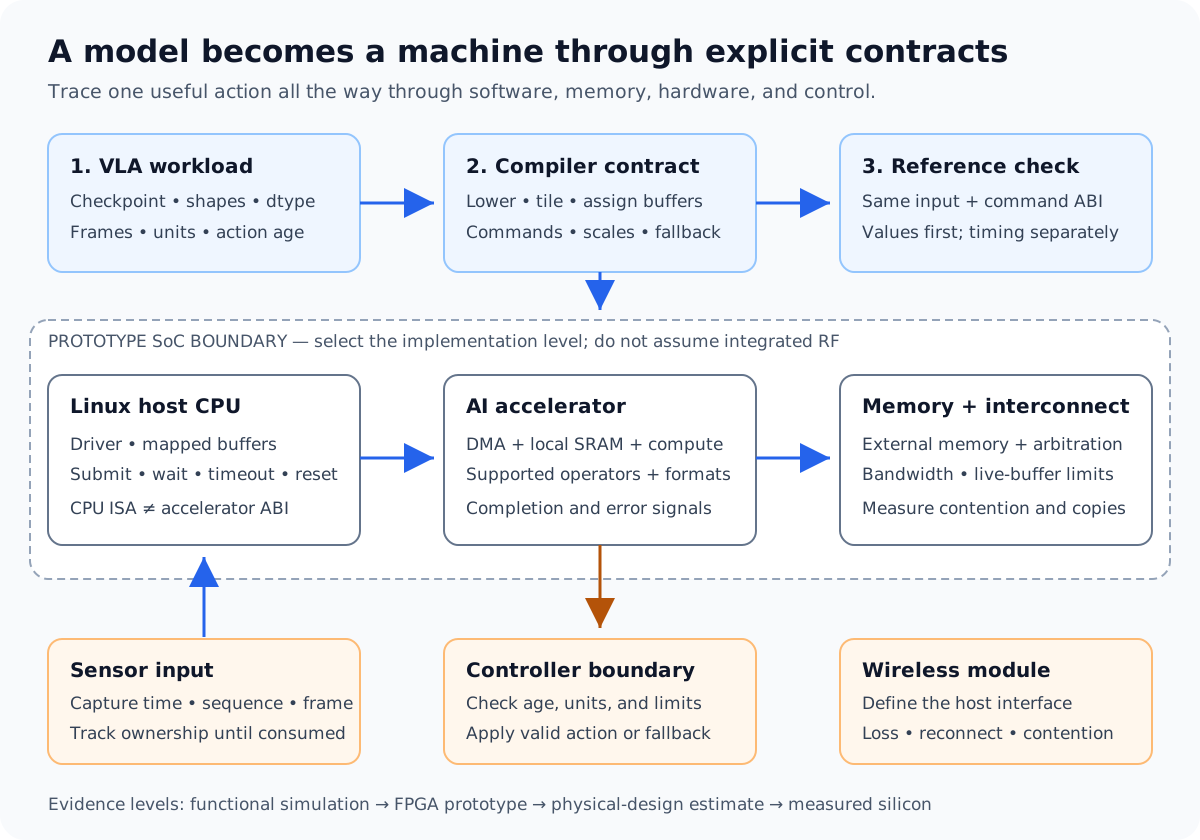
Added an original model-to-SoC PNG, editable SVG, and provenance/regeneration note. The rendered image was inspected and text adjusted to avoid overlap. It represents conceptual interfaces, not a verified floorplan or integrated-RF design.
Checked arithmetic for tile SRAM, conventional GQA KV storage, raw quantized storage, and AllReduce bandwidth examples. Local Markdown targets in this scope passed the repository link checker during integration; full-site validation is recorded by the coordinating review. git diff --check passed at handoff.
No GPU, RDMA, camera, vehicle, FPGA, RTL simulator, EDA, TRACE32, or silicon experiment was executed in this review. The remaining historical deep-dive commands and lecture code sketches are not certified runnable on October 2026 packages. In particular, the large H200/L40S/NCCL/GDS lecture sets received entry/selected-claim review rather than a full lab rerun; tinygrad and MLIR APIs still require a pinned environment. Agentic Chip Design lectures 02–09 remain explicitly planned; its new workshop makes the existing opener actionable without representing missing lectures as completed content.